Main / Data / Components
Components
Component-level directory — reducers, motors, sensors, compute. The parts that decide what a robot can actually do. · 0 components
Data compiled by behindrobotics.com · last updated Aug 2026
← Back to components
Faive Hand
Overview
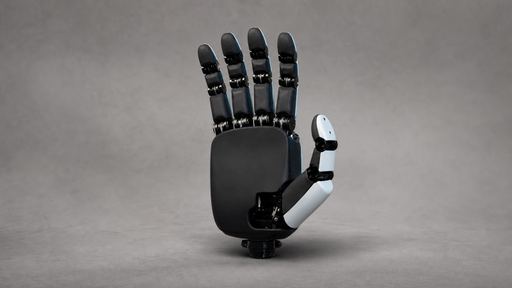
3D-printable, tendon-driven hand using a biomimetic rolling-contact-joint design from the ETH Zurich Soft Robotics Lab.
Specification
Category
Hands & Grippers
Origin
 Switzerland
Spec
hand dof: 20 DOF (11 actuated), tendon-driven
Other Hands & Grippers — 12 tracked
2F-140 Adaptive Gripper
Robotiq
2FG14 Finger Gripper
OnRobot
3-Finger Adaptive Robot Gripper
Robotiq
3FG25 Finger Gripper
OnRobot
Ability Hand
PSYONIC
Aero Hand Open
Chestnut Robotics
AG Collaborative Gripper Series
ChangingTek Robotics
AgiBot OmniHand 3 Ultra-M
AgiBot (智元机器人)
AIDIN-Hand
Aidin Robotics
Allegro Hand V5 Plus
Wonik Robotics
Amazing Hand
Pollen Robotics
Apex Hand
Dexcel Robotics
Figures as recorded by behindrobotics.com from component and supplier data. Verify before citing.