Main / Data / Components
Components
Component-level directory — reducers, motors, sensors, compute. The parts that decide what a robot can actually do. · 0 components
Data compiled by behindrobotics.com · last updated Aug 2026
← Back to components
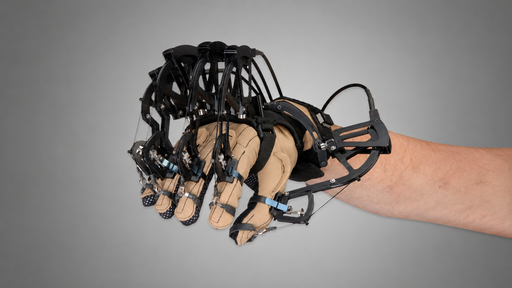
CyberGlove III
CyberGlove Systems · Hands & Grippers ·  United States · Visit CyberGlove Systems’s company profile →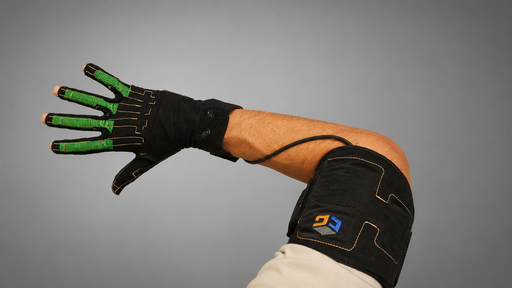
Overview
sensor count: 18 or 22 sensors; sensor repeatability: 3 degrees average standard deviation between wearings; sensor linearity: maximum 0.6% standard deviation nonlinearity over full joint range
Specification
Category
Hands & Grippers
Origin
United StatesSpec
sensor count: 18 or 22 sensors; sensor repeatability: 3 degrees average standard deviation between wearings; sensor linearity: maximum 0.6% standard deviation nonlinearity over full joint range
Other Hands & Grippers — 12 tracked
2F-140 Adaptive Gripper
Robotiq
2FG14 Finger Gripper
OnRobot
3-Finger Adaptive Robot Gripper
Robotiq
3FG25 Finger Gripper
OnRobot
Ability Hand
PSYONIC
Aero Hand Open
Chestnut Robotics
AG Collaborative Gripper Series
ChangingTek Robotics
AgiBot OmniHand 3 Ultra-M
AgiBot (智元机器人)
AIDIN-Hand
Aidin Robotics
Allegro Hand V5 Plus
Wonik Robotics
Amazing Hand
Pollen Robotics
Apex Hand
Dexcel Robotics
Other components from CyberGlove Systems
Figures as recorded by behindrobotics.com from component and supplier data. Verify before citing.